img

VTC-40C Automation

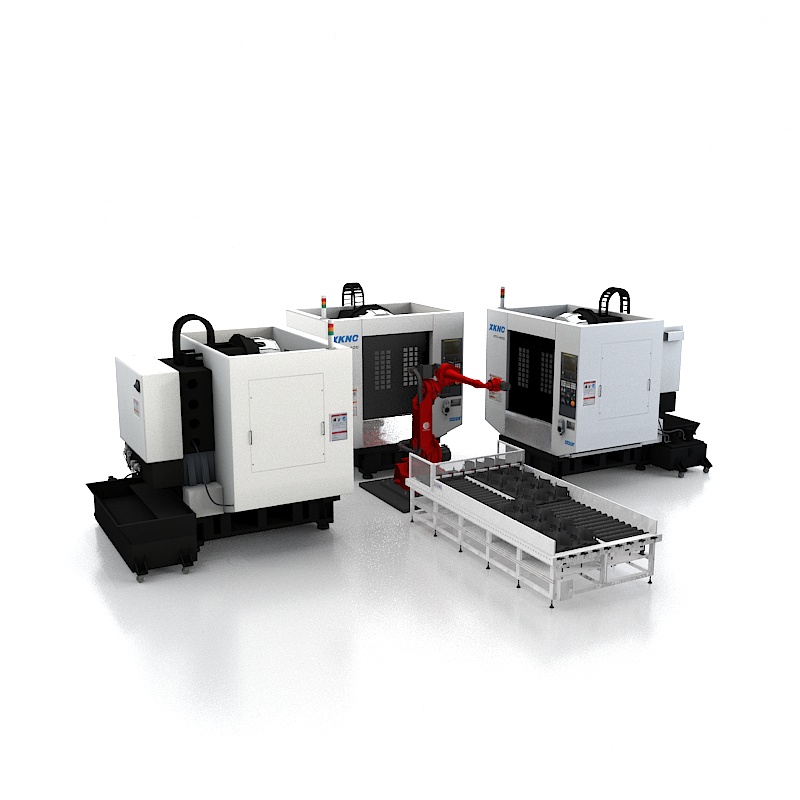
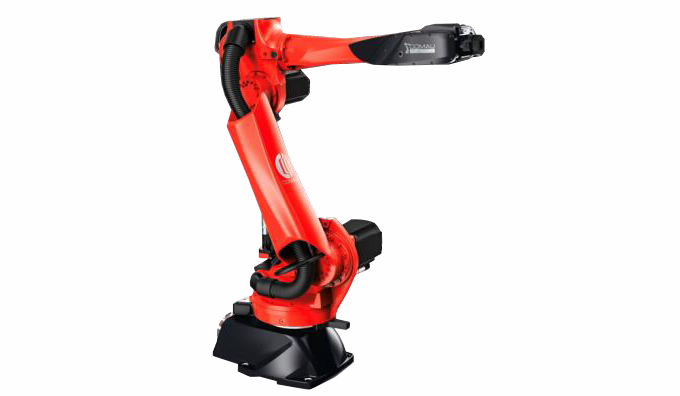
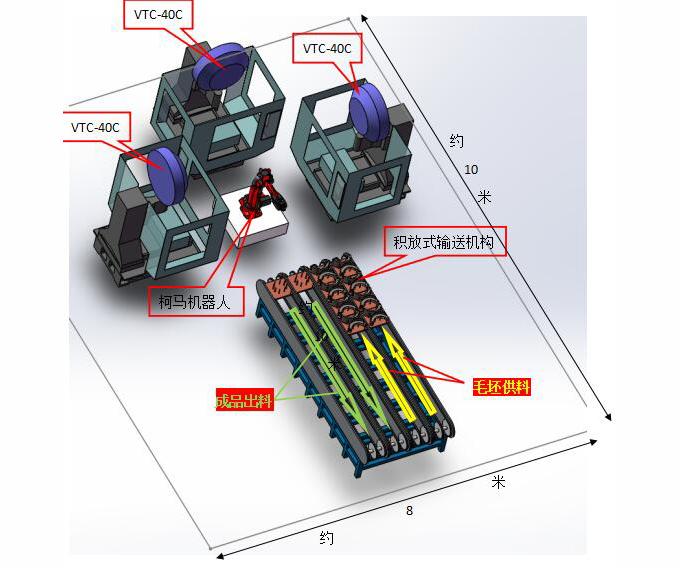
Three XKNC VTC-40C small vertical machining centers are used for parts processing; the flow of parts between the feeding/receiving mechanism and the machine tool is completed by a Comau 60 kg NJ60-2.2 robot with an end effector; The storage of blanks and finished products is completed by a set of accumulation conveying mechanism; the scheme adopts a one-to-three layout, that is: one robot automatically loads and unloads three processing centers;

Performance Characteristics
Technical Parameter
Typical Parts
Processing Video
  • 1.零件加工

    40C副本.png

    XKNC-VTC40C

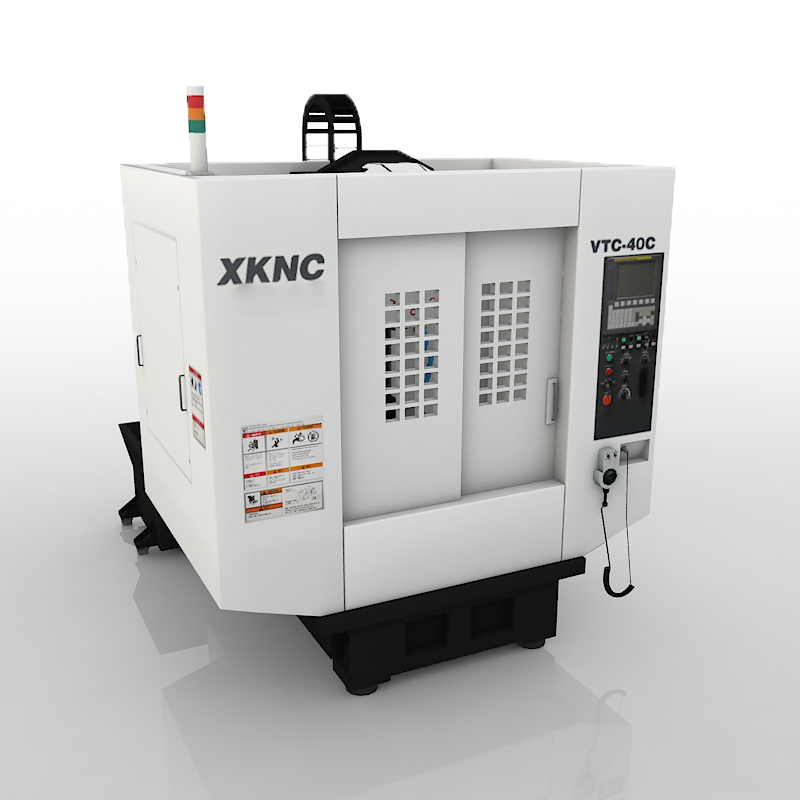
    The machining of the parts is processed by the Bukchon XKNC-VTC40C machining center. The machine has 14 tool magazines. The item exchange is the tool body without moving, the tool exchange is fast and reliable, and the preparation time is greatly shortened. The high-speed spindle maintains stable precision even under high-speed cutting.

  • 2.Machine tool clamping

    5 工装夹具.jpg

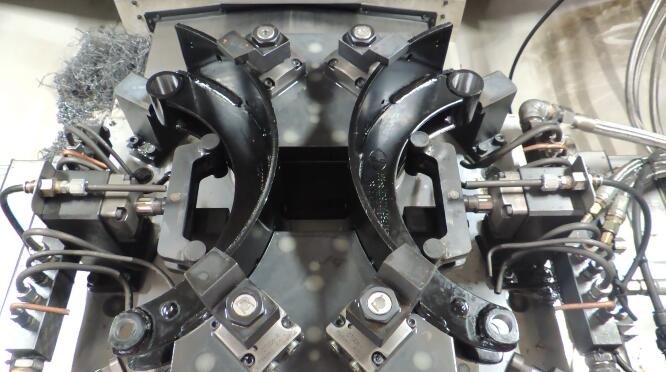
    The machine tool clamp adopts special hydraulic clamp. The clamp can clamp two workpieces at a time. The workpiece clamping direction is basically the same as that on the feeding tray. When the robot puts the blank into the fixture, the fixture automatically takes the part. Push to the positioning surface and clamp.

  • 3.Material flow

    4 COMAU机器人.jpg

    Comau NJ60-2.2 robot

    The flow between the machine and the storage mechanism is completed by the Comau 60 kg NJ60-2.2 robot with the end effector. The robot firstly grabs the finished parts on the machine and puts it into the finished product of the accumulation transmission mechanism. The tray is collected, and then 2 blanks are grabbed on the feeding tray for feeding the machine. At this point, both the feed conveyor and the finished conveyor are moved forward one station, and the next tray is ready for the next automatic loading and unloading.

    The robot cooperates with the accumulation transmission mechanism to automatically feed three machining centers at the same time.

  • 4.Compact layout

    1 整体布局.jpg

    Three XKNC KIRA-VTC-40C mini vertical machining centers are used for part processing; the flow between parts in the feeding/receiving mechanism and the machine tool is completed by a Comau 60 kg NJ60-2.2 robot with end effector. The storage of parts blanks and finished products is completed by a set of accumulation conveyors; the scheme adopts a one-to-three layout, that is, one robot automatically feeds and unloads three machining centers;

  • 5.Blank supply

    2 积放式输送机构.jpg

    Accumulative transmission mechanism

    3 积放式输送机构.jpg

    Accumulative transmission mechanism

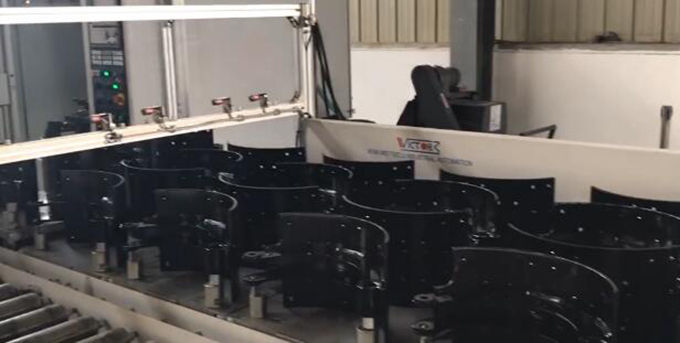
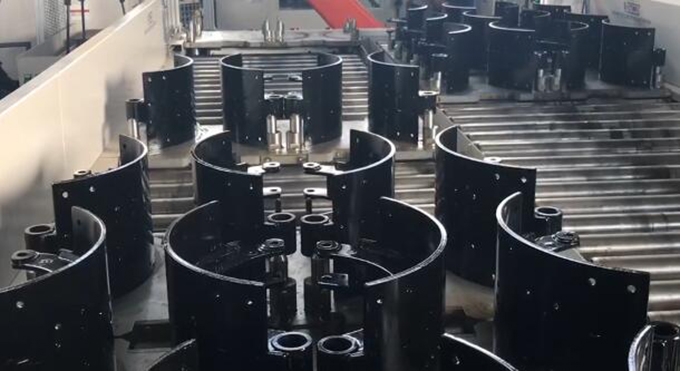
    The automatic feeding of the part blank is completed by a stacking transfer mechanism. The mechanism is divided into 4 transport lanes, 2 of which are responsible for blank feeding, and the bottom rotating system drives the pallet to move, and each tray can be placed 2 Parts.

    The agency, in conjunction with the Comaudo articulated robot, can automatically feed three machining centers simultaneously.

(1)机械本体标准规格MACHINE SPECIFICATIONS

项目Items

参数Parameter

刀库Magazine tool

刀库容量Magazine tool capacity

14把

自动换刀形式Automatic tool change form

自动Automatic

刀柄规格Tool holder spec

MAS-BT40

拉钉规格Blind rivet spec

MAS-P40T-1

最大刀具长度Max.tool length

250mm

最大刀具直径Max.tool diameter

100mm

最大刀具重量Max.tool weight

4kg

换刀时间(T-T)Tool to tool(T-T)

1.6sec

换刀时间(C-C)Tool to tool(C-C)

3.2sec*1

主轴Spindle

主轴最高转速Max.spindle rotate speed

MAX.6000r/min

MAX.10000r/min

最大攻丝速度Max.tapping speed

4000r/min

主轴孔锥度Spindle hole conical degree

BT40 7:24

工作台Workbench

工作台载重Workbench load

300kg

工作台尺寸(长×宽)Workbench size(L×W)

800mm×400mm

速度Speed

快移速度(X/Y/Z)Rapid traverse speed(X/Y/Z)

X/Y轴:36m/min  Z轴:48 m/min

X/Y axis:36m/min  Z axis:48 m/min

切削进给速度(X/Y/Z)Cutting feed speed(X/Y/Z)

Max. 10m/min

精度Precision

X/Y/Z定位精度X/Y/Z Positioning accuracy

±0.005mm(全行程)*2

X/Y/Z重复定位精度X/Y/Z Repeated Positioning accuracy

±0.003mm*2

行程Travel

X轴行程X-axis travel

700mm

Y轴行程Y-axis travel

470mm

Z轴行程Z-axis travel

400mm

主轴端面至工作台面距离Distance from spindle and face  to workbench

155mm-555mm

驱动电机Driving Motor

主轴伺服电机Spindle servo motor

5.5/7.5KW

进给(X/Y/Z轴)伺服电机Feed servo motors

X/Y轴:1.8kw  Z轴: 2.7kw

X/Y axis:1.8kw  Z axis: 2.7kw

冷却Cooling

冷却泵流量Cooling pump flow

120L/min

其它Etc

总电气容量Required electric power

15KVA, AV200V±10%,50HZ

气源压力Air source pressure

0.4MPa

气源流量Air source flow

100NL/min

机床尺寸(长×宽×高)Floor space(L×W×H)

2627mm×1959mm×2780mm

机床重量Machine tool weight

约2620kg

型号Model

RB20

手臂形式Type

水平多关节(SCARA)

控制轴数Controlled Axis

4轴  4- Axis

伺服系统Servo System

全数字交流伺服系统

最大负载能力Payload

20kg

最大回转半径 MAX turning radius

1200 mm

动作范围Range of Motion

直线轴(3 轴)UP/DOWN

570 mm

大臂转轴(1轴)Lower arm

±90°

小臂转轴(2 轴)Upper arm

±116°

腕部旋转(4 轴)Wrist twist

±720°

最高速度Maximum Speed

直线轴(3 轴) UP/DOWN

12.5m/min

大臂转轴(1轴)Lower arm

150°/ s

小臂转轴(2 轴)Upper arm

150°/ s

腕部旋转(4 轴)Wrist twist

600°/ s

允许扭矩 Allowable Moment

大臂转轴(1轴)Lower arm

675.5 Nm

小臂转轴(2 轴)Upper arm

193.6 Nm

腕部旋转(4 轴)Wrist twist

31.75 Nm

允许惯性矩 Allowable Inertia

大臂转轴(1轴)Lower arm

13.05 kg.m2

小臂转轴(2 轴)Upper arm

1.03 kg.m2

腕部旋转(4 轴)Wrist twist

0.0276 kg.m2

重复定位精度  Repeatability

单位(mm)

±0.1 mm

本体重量   Weight

300kg

周围运行环境Ambient Conditions

温度 Ambient temperature℃

0℃~+40℃

相对湿度Humidity

20至85%RH(不结露)

其他Others

●避免易燃、腐蚀性气体、液体Free from corrosive gasses or liquids, or explosive gasses

●勿溅水、油、粉尘等

Clean and dry

●远离电器噪音源(等离子)

Free from excessive electrical noise (plasma)

(2)CNC装置标准规格CNC UNIT SPECIFICATIONS

项目Items

内容Contents

控制系统Control unit

FANUC 0i mate MD

控制轴数Controlled axis

最大控制轴数4轴,同时控制3轴Number of max. control axises:4axises number simultaneous control axises

输入指令Input instruction

最小设定单位:0.001mm Minimum Setting: 0.001mm

最小移动单位:0.001mm Minimum Travel Setting: 0.001mm

绝对/增量指令Absolute/incremental code


VIEWO LIST

  • Figure

    骏捷项目Junjie Project

    https://cdn.nagashima-seiko.com/uploads/20210315/6aed3bd23921a6c6230aeb69c915fdf3.mp4
imh
Navigation Bar
img
img